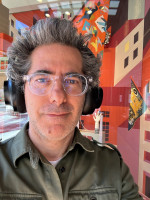
Baran Çürüklü, Senior Lecturer


Baran Çürüklü received the Ph.D. degree in computer science from Mälardalen University, Västerås, Sweden, in 2005. He is currently a Senior Lecturer in artificial intelligence with Mälardalen University. His earlier research addressed computational models of information processing in the mammalian visual cortex. Since 2007, his work has focused on artificial intelligence, robotics, human–robot interaction, multi-agent systems, and the coordination of heterogeneous autonomous systems. He has participated in and led research activities in several Swedish and European projects, including DPAC, SWARMs, eCraft2Learn, AFarCloud, and SECO Collab. He is the Project Coordinator of NexTArc, a Chips Joint Undertaking project on trustworthy and energy-efficient embedded AI, and leads the ethics, legal, and safety work package in the European Defence Fund project STRATUS. His current research interests include multi-agent mission planning, human–autonomy collaboration, trustworthy embedded AI, and the ethical and safety aspects of autonomous systems.

[Show all publications]

[Google Scholar author page]

Latest publications:

A safety-driven architectural framework for fail-operational drone swarms in critical missions (Sep 2026)
Luiz Giacomossi, Zafer Yigit, Marwan Shakarna , Shoaib Saleemi , Ivan Tomasic, Baran Çürüklü, Håkan Forsberg
Proceedings of the 45th Digital Avionics Systems Conference (DASC 2026)

From Noisy Commands to Multi-UAV Missions (Sep 2026)
Afshin Ameri E., Luiz Giacomossi, Håkan Forsberg, Baran Çürüklü
2026 MIPRO Robotics Technologies and Applications Conference (MIPRO R 2026)

Can Linux Fly a Drone? A Flight Control Evaluation for Unified UAV Architectures Using PREEMPT_RT Kernel (Sep 2026)
Luiz Giacomossi, Håkan Forsberg, Ivan Tomasic, Baran Çürüklü, Tommaso Cucinotta , Afshin Ameri E.
31st IEEE International Conference on Emerging Technologies and Factory Automation (ETFA2026)

Market-Based Replanning for Safety-Critical UAV Swarms in Search and Rescue Missions (May 2026)
Luiz Giacomossi, Andrea Haglund , Claire Namatovu , Emily Zainali , Esaias Målqvist , Yonatan Beyene , Ivan Tomasic, Baran Çürüklü, Håkan Forsberg
MIPRO 2026 - 49th ICT and Electronics Conventions (MIPRO 2026)

RELIANT Overview 2025 (Sep 2025)
Kristina Lundqvist, Mikael Sjödin, Malin Rosqvist, Federico Ciccozzi, Cristina Seceleanu, Baran Çürüklü

Synthesis and Verification of Mission Plans for Multiple Autonomous Agents under Complex Road Conditions (Jun 2024)
Rong Gu, Eduard Baranov , Afshin Ameri E., Eduard Paul Enoiu, Baran Çürüklü, Cristina Seceleanu, Axel Legay , Kristina Lundqvist
ACM Transactions on Software Engineering and Methodology (TOSEM)

PhD students supervised as assistant supervisor:

Afshin Ameri E.
Branko Miloradovic (former)
Elias Kettunen
LanAnh Trinh (former)
Mirgita Frasheri (former)
Sepehr Mousavi

MSc theses supervised (or examined):
Thesis TitleStatus
available
selected
Cognitive Robotics selected
Computer based modeling of the mammalian neocortex selected
Models of Biological Neural Networks selected
On the Feasibility of Low Cost Computer Vision selected
Environment Mapping with a Kinect Sensor Using Industrial Robots in progress
Multi-drone Control System in progress
Music in Motion - Smart Soundscapes in progress
Solving flow shop problems using a forward-chaining partial-order planner in progress
Språkteknologiförstärkt matchning för att identifiera liknande produkter in progress
Using an evolutionary algorithm to search for control algorithm parameters with a quadrocopter as hardware in the loop in progress
A Brain-Actuated Robot Controller for Intuitive and Reliable Maneuvering finished
Adaptive autonomy with unreliable communication finished
Analysis of complete systems through computer vision finished
Analysis of similarity and differences between articles using semantics finished
Artificial Life, A Model finished
Auditory Cortex in FPGA finished
AUTOMATIC PLANNING OF COLLABORATING AUTONOMOUS UNMANNED AERIAL VEHICLES finished
Autonomous robot with human detection and obstacle avoidance finished
BIOMEDICAL ENGINEERING, GRAPHIC INTERFACE FOR DATA TAKEN WITH FPGA finished
Brain computer interface using EEG finished
Grammar recognition using biologically inspired spiking networks finished
How to get the maximum benefits from TQM and Management System for better project results? finished
Implementation of an artificial neuron in VHDL finished
Innovation Diffusion in Scale-Free Networks: Signal Analysis in Complex Networks finished
Interaktiva multidisciplinära konstnärliga upplevelser i unika miljöer – digital förstärkning av scenkonst finished
Loopaggregering ur stora audioströmmar finished
Myoelectric Interface finished
Planning of Robot Behaviour finished
Processing RAW image data in mobile units finished
Programming and control of a robot with gestures – A novel approach to human-robot interaction finished
Recording of muscles activities (EMG) to detect hand and arm movements finished
Region-based multi-focus image fusion using image histogram comparison finished
Semantic Analysis of Natural Language and Definite Clause Grammar using Statistical Parsing and Thesauri finished
SIGNAL PROCESSING AND DATA TRANSMISSION USING A FPGA finished
The Python neural simulation technology graphical user interface finished
Unified Incremental Multimodal Interface for Human Robot Interaction finished
Unsupervised sequence learning using biological neural networks finished
Using Artificial Intelligence to Verify Authorship of Anonymous Social Media Posts finished
Using Wii motion sensing controls for industrial applications finished
VR-flygsimulatorer, för ökad upplevelse och som läroverktyg i flygutbildningar finished
Wide Area Motion Capture using Array of Consumer Grade Structured Light Depth Sensors finished
Övervakning av fordonsanvändning och fordonsekonomi i transportbranschen finished